PhD story
Teaching robots the language of touch.
My PhD at U2IS, ENSTA Paris (IP Paris), told as a storyboard: the question, the hardware, the models and the experiments, and the engineering skills each step built.
The question
Robots are moving into hospitals, homes and care settings, where they will touch people. Vision and speech are mature; touch is not. How should a robot sense human touch, and how should it touch back?
Transferable skillsproblem framingliterature reviewresearch planning
A silicone tactile skin
I designed, built and calibrated a tactile array embedded in a soft silicone substrate for a humanoid hand, sensitive enough for a caress and robust enough for a firm grip.
Transferable skillssensor designfabricationcalibrationembedded acquisition
Read more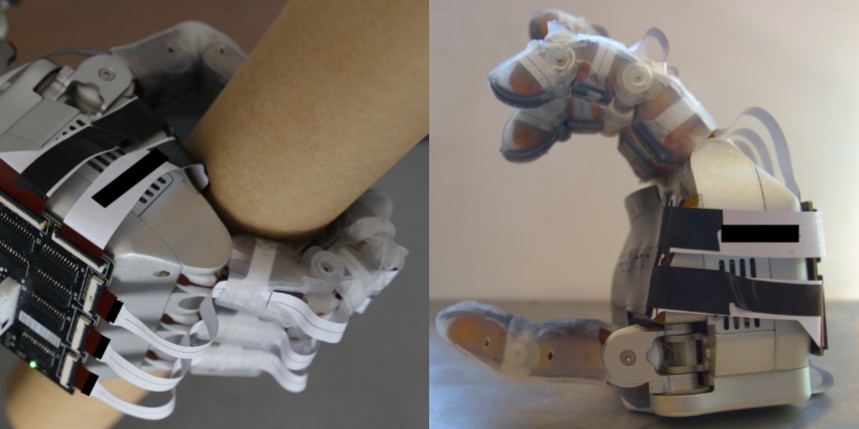
From pressure to meaning
Real-time models turn raw taxel pressure into hand shape and grasping behaviour, so the robot can tell who is holding it and how (ICSR 2025).
Transferable skillsreal-time signal processingestimationmachine learning
Read more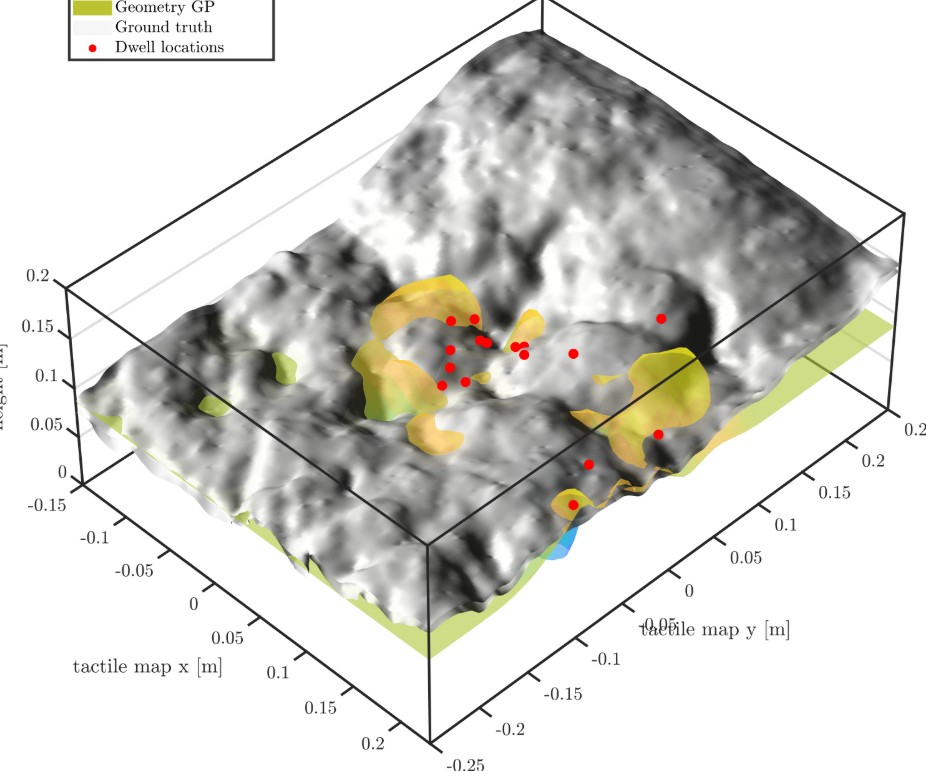
Predicting touch before it happens
A generative, factorised model of action-conditioned tactile affordance: the robot learns what it should feel when it presses, strokes or grasps, and notices when reality differs.
Transferable skillsgenerative modelsdataset designPyTorch
Read moreThe handshake study
On a Franka Panda arm, I varied compliance, grip force and synchrony, and measured how natural each handshake felt. Softness and anticipation win (first-author paper, ICRA 2026).
Transferable skillsexperimental designuser studiesstatisticsrobot control
Read more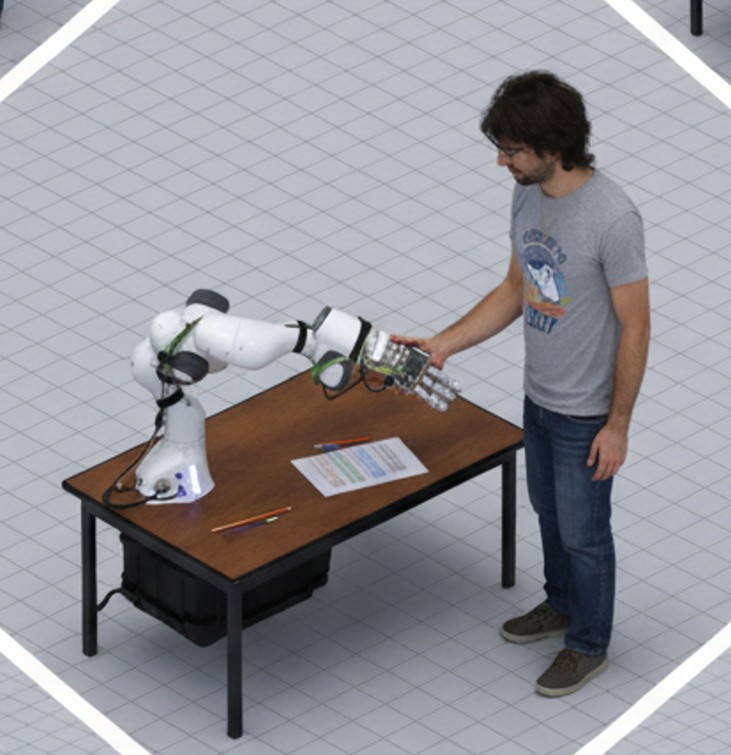
Touch that calms
A soft pneumatic interface lets a humanoid breathe and beat like a heart under your hand; guided breathing with it reduced reported anxiety (Humanoids 2024, ICSR).
Transferable skillssoft actuationpneumaticsphysiological measures
Read more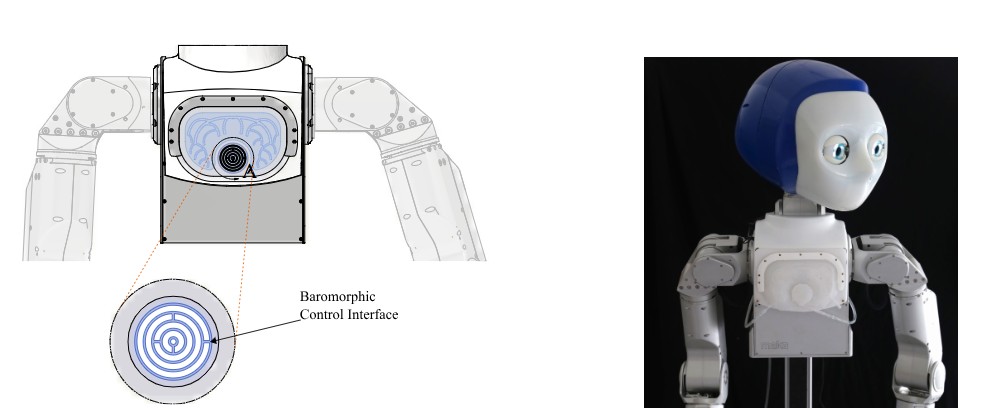
Building the community
I co-organised Beyond Words 1 and 2, the ICSR workshops on the role of touch in social robotics, bringing robotics, neuroscience and design researchers together.
Transferable skillsevent organisationscientific communication
Read more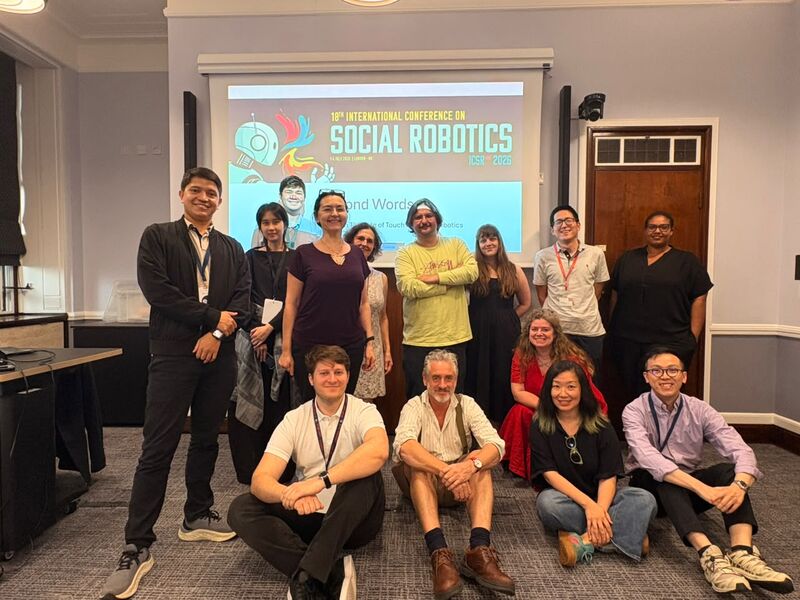
What's next
Scaling the skin to the whole hand and arm, learning on the robot itself, and taking touch-aware robots towards care settings, with open-source software and hardware.
Read more